

Lead application nm measurement and structuring of objects
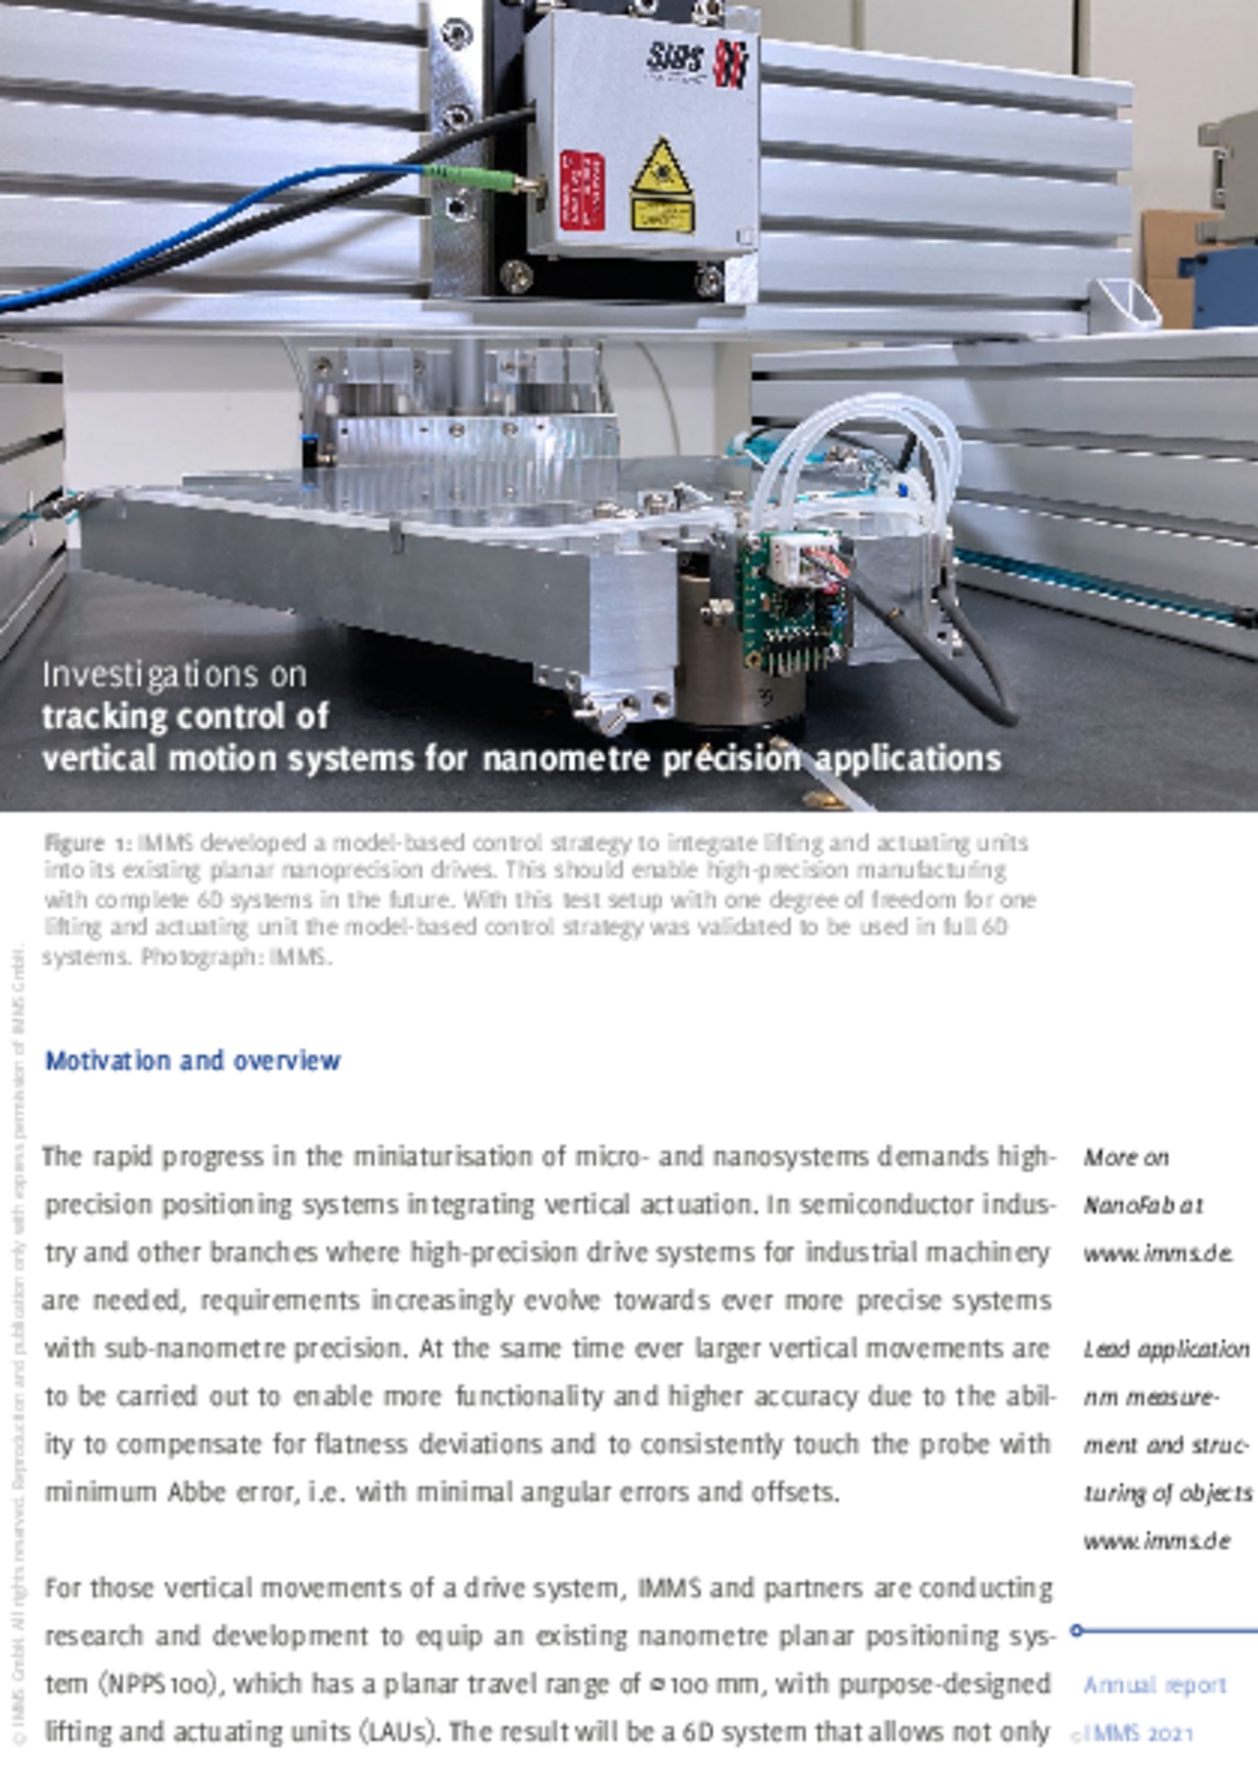
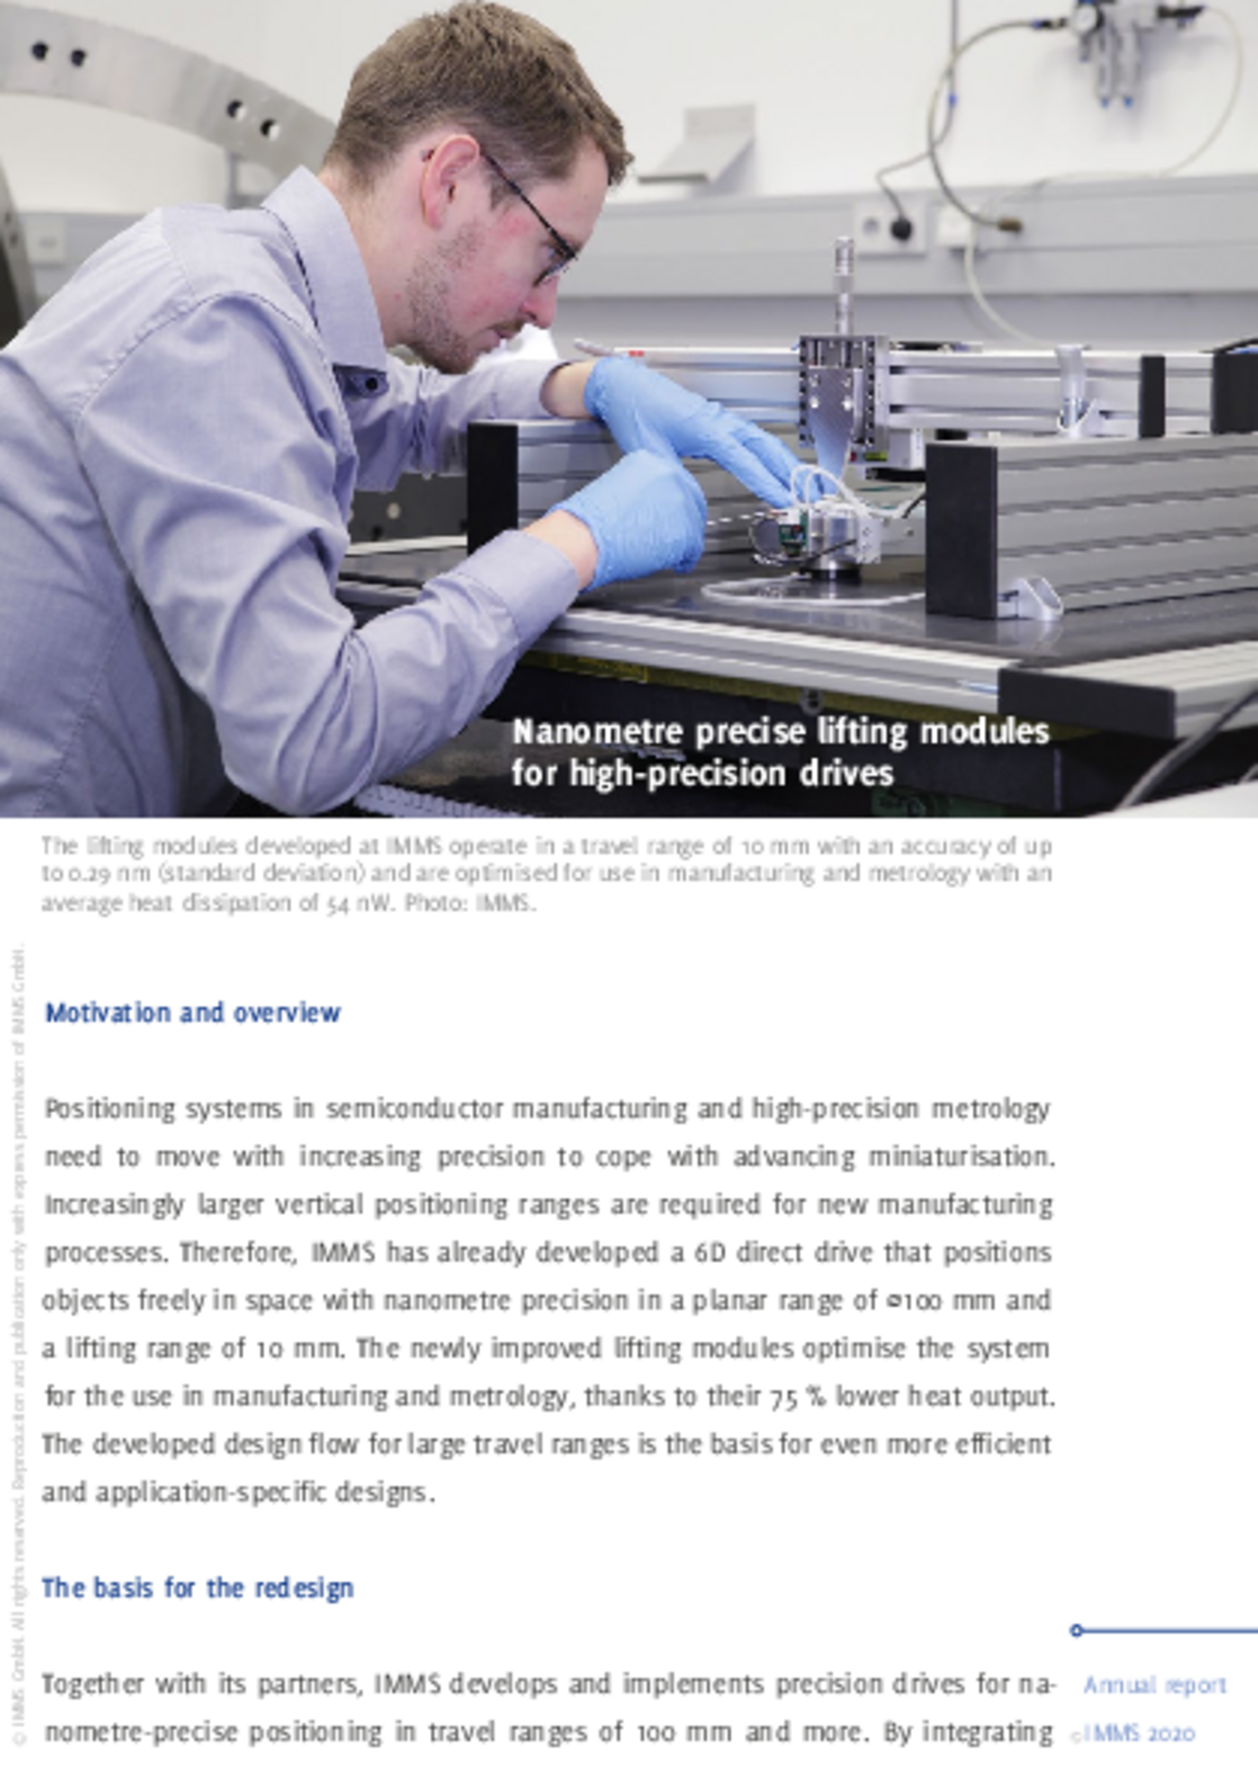
Our goal is to create the basis for the measurement and manufacturing technology of the future with high-precision drive systems. From today’s planar (2.5D) motion accuracies in the sub-µm range, we are on the way to spatial (6D) positioning accuracies in the single-digit nm range. On the basis of our research, we are developing actuators that make it possible to position an object on a surface with a diameter of 100 mm and a vertical stroke of 10 mm with nanometre precision. In perspective, the diameter will be extended to 200 mm and the z-stroke to 25 mm. Such systems are used, for example, in precision metrology and for the production of semiconductor wafers and exposure masks in microelectronics manufacturing.
Contact
Contact
Dr.-Ing. Ludwig Herzog
Head of Mechatronics
ludwig.herzog(at)imms.de+49 (0) 3677 874 93 60
Dr. Ludwig Herzog will provide detail on our research on magnetic 6D direct drives with nm precision for the nm measurement and structuring of objects. He supports you with services for the development of mechatronic systems, for simulation, design and test of MEMS as well as for finite element modelling (FEM) and simulation.
Related content
Project
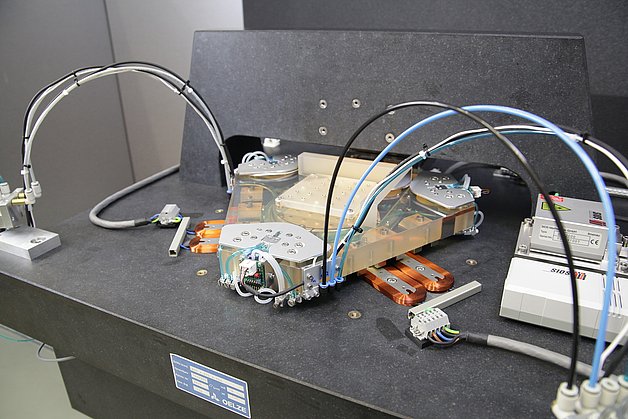
MC_NPS
Combination of a high-precision drive from research with industrial control for nanometre-precise positioning in high-tech applications
Project
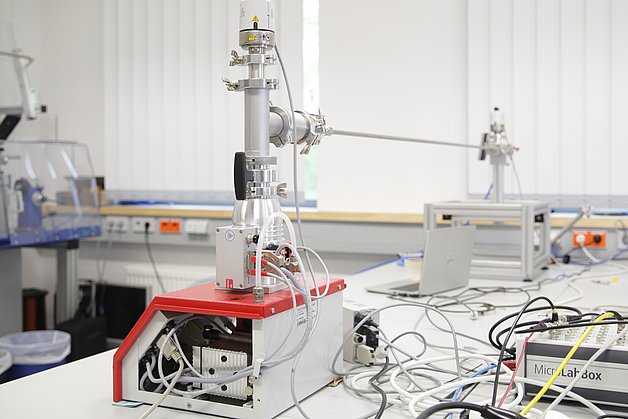
OptoMed vacuum air bearings
Air bearings in high-precision vacuum applications? Together with our partners, we are exploring the technical feasibility of this (apparent) contradiction.

Project
NFM-100
For fundamental research on nanometrology and nanofabrication at Ilmenau TU, the nanofabrication machine NFM-100 was realised as a system which enables the scanning of surfaces (AFM) as well as the processing by field emission scanning probe lithography for the first time in an xy-travel range of Ø100 mm.
Project
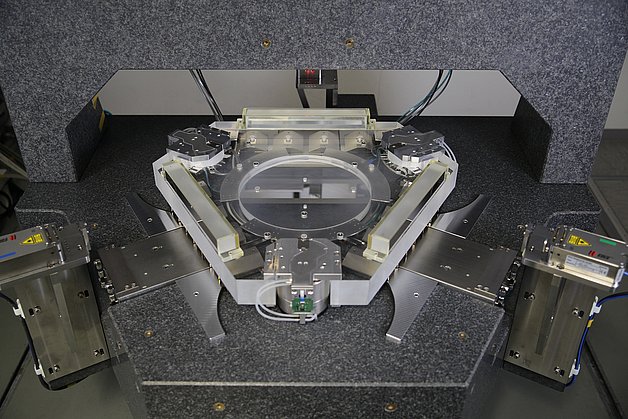
K4PNP+Z
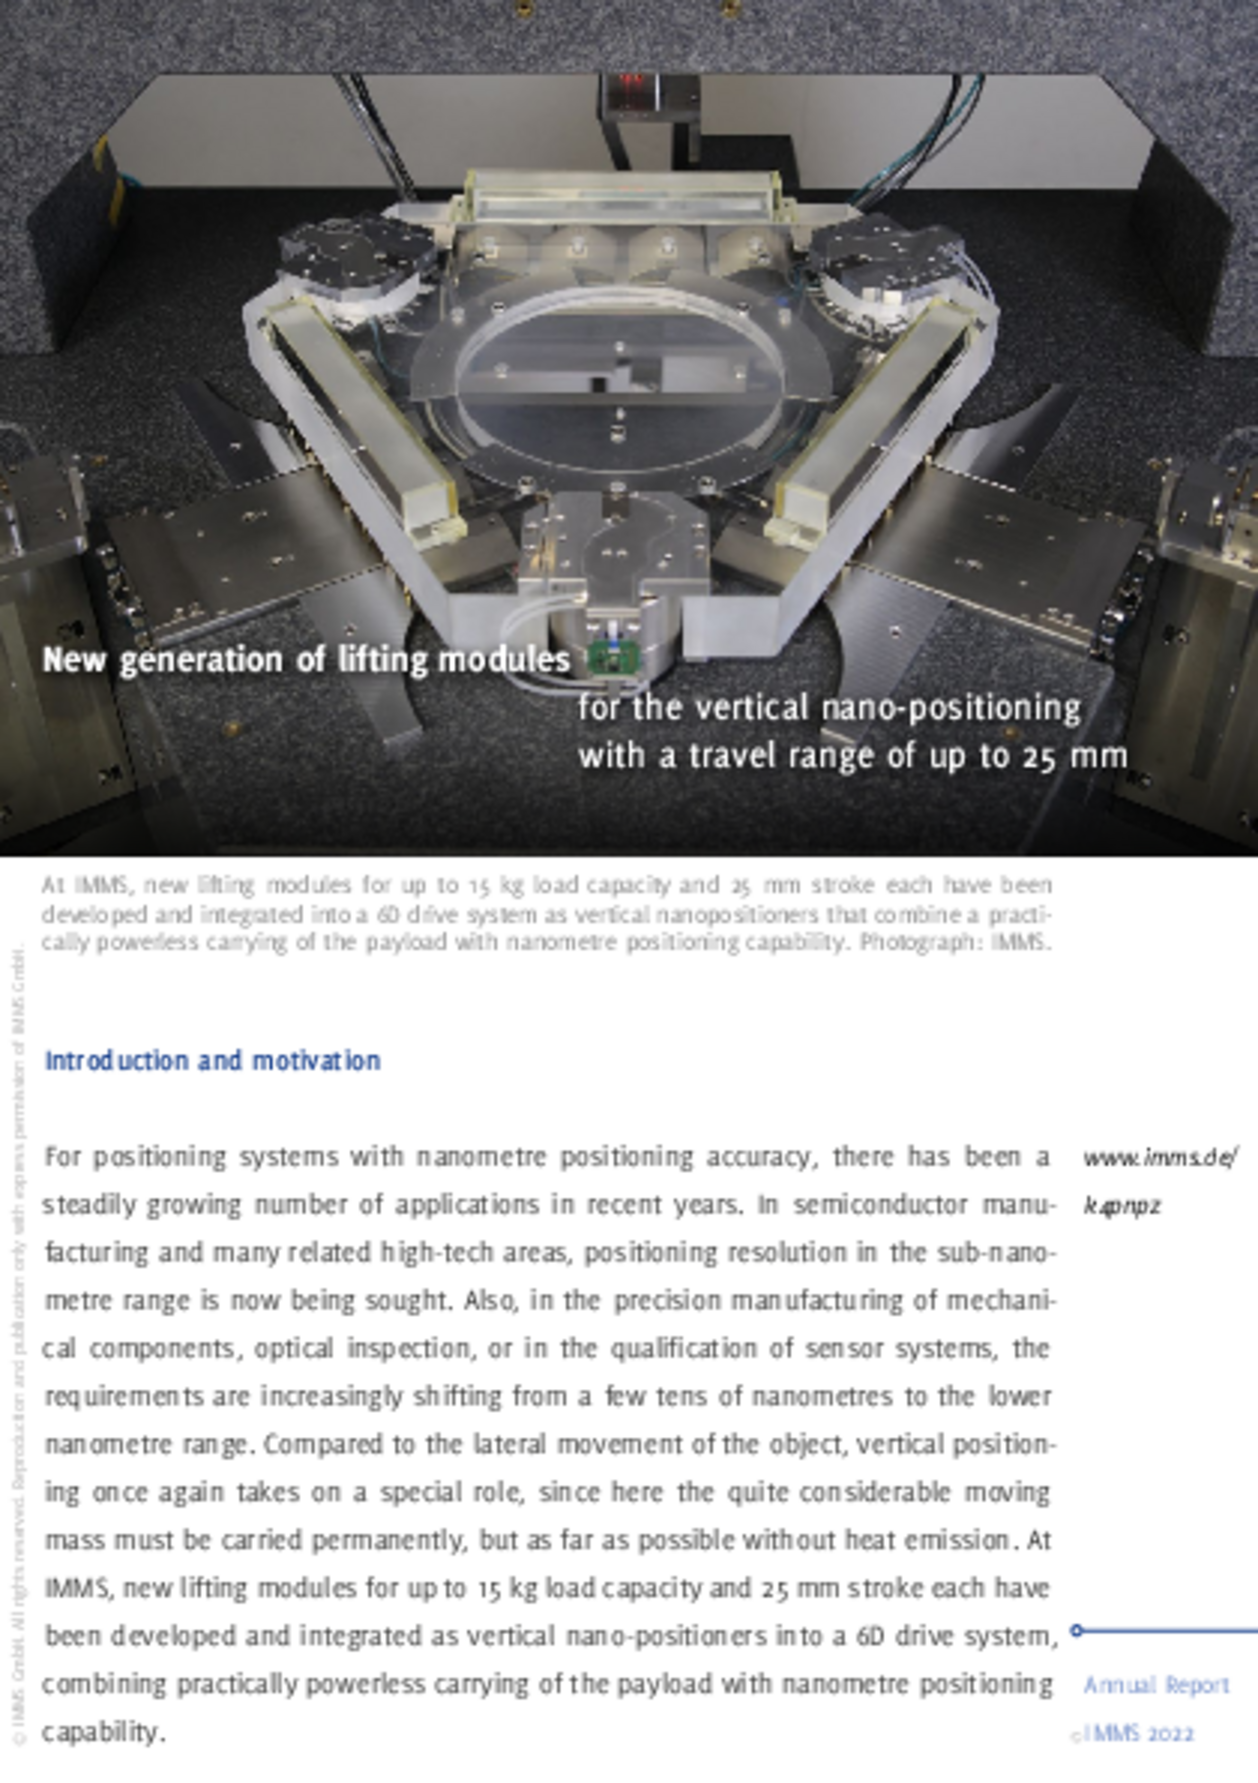
IMMS developed actuators to position objects in planes with diameters up to 200 mm and a vertical stroke of 25 mm with nanometre precision.

Reference
Michael Muth, AeroLas
“We have for many years been appreciative of our cooperation with IMMS. The results from this project will be the basis of product design to the specification of future AeroLas customers. IMMS will likewise be an important partner for us in future developments because of its outstanding expertise in the field of magnetic drives.“
Reference
Peter Chall, ALSI
”The achieved extreme precision, reproducibility and productivity of the laser dicing technology are at the forefront of international excellence. The close cooperation with IMMS leads to innovative developments, which is a basis that we can count on to expand our position as a leading technology provider.“
Nonholonomic Omnidirectional Mobile Robot with Dual Steerable Drive Modules – Part I: Modeling
Alex S. Huaman1, Michael Katzschmann1, Tom Mehner2, Johann Reger32026 30th International Conference on Methods and Models in Automation and Robotics (MMAR), , Międzyzdroje, Poland, pp. 226-231, DOI: doi.org/10.1109/MMAR70562.2026.116678611IMMS Institut für Mikroelekronik- und Mechatronik-Systeme gemeinnützige GmbH (IMMS GmbH), Ehrenbergstraße 27, 98693 Ilmenau, Germany, 2MetraLabs GmbH, Weimarer Str. 28, 98693 Ilmenau, Germany, 3Technische Universität Ilmenau, 98684 Ilmenau, P.O. Box 10 05 65, GermanyNonholonomic Omnidirectional Mobile Robot with Dual Steerable Drive Modules – Part II: Tracking Control
Alex S. Huaman1, Michael Katzschmann1, Tom Mehner2, Johann Reger32026 30th International Conference on Methods and Models in Automation and Robotics (MMAR), , Międzyzdroje, Poland, pp. 232-237, DOI: doi.org/10.1109/MMAR70562.2026.116678641IMMS Institut für Mikroelekronik- und Mechatronik-Systeme gemeinnützige GmbH (IMMS GmbH), Ehrenbergstraße 27, 98693 Ilmenau, Germany, 2MetraLabs GmbH, Weimarer Str. 28, 98693 Ilmenau, Germany, 3Technische Universität Ilmenau, 98684 Ilmenau, P.O. Box 10 05 65, GermanyNonholonomic Omnidirectional Mobile Robot with Dual Steerable Drive Modules – Part III: Steering Control
Alex S. Huaman1, Michael Katzschmann1, Tom Mehner2, Johann Reger32026 30th International Conference on Methods and Models in Automation and Robotics (MMAR), , Międzyzdroje, Poland, pp. 238-243, DOI: doi.org/10.1109/MMAR70562.2026.116678971IMMS Institut für Mikroelekronik- und Mechatronik-Systeme gemeinnützige GmbH (IMMS GmbH), Ehrenbergstraße 27, 98693 Ilmenau, Germany, 2MetraLabs GmbH, Weimarer Str. 28, 98693 Ilmenau, Germany, 3Technische Universität Ilmenau, 98684 Ilmenau, P.O. Box 10 05 65, GermanyInvestigation of long-term distance measurement repeatability in a large-range nanopositioning machine combined with a laser focus sensor
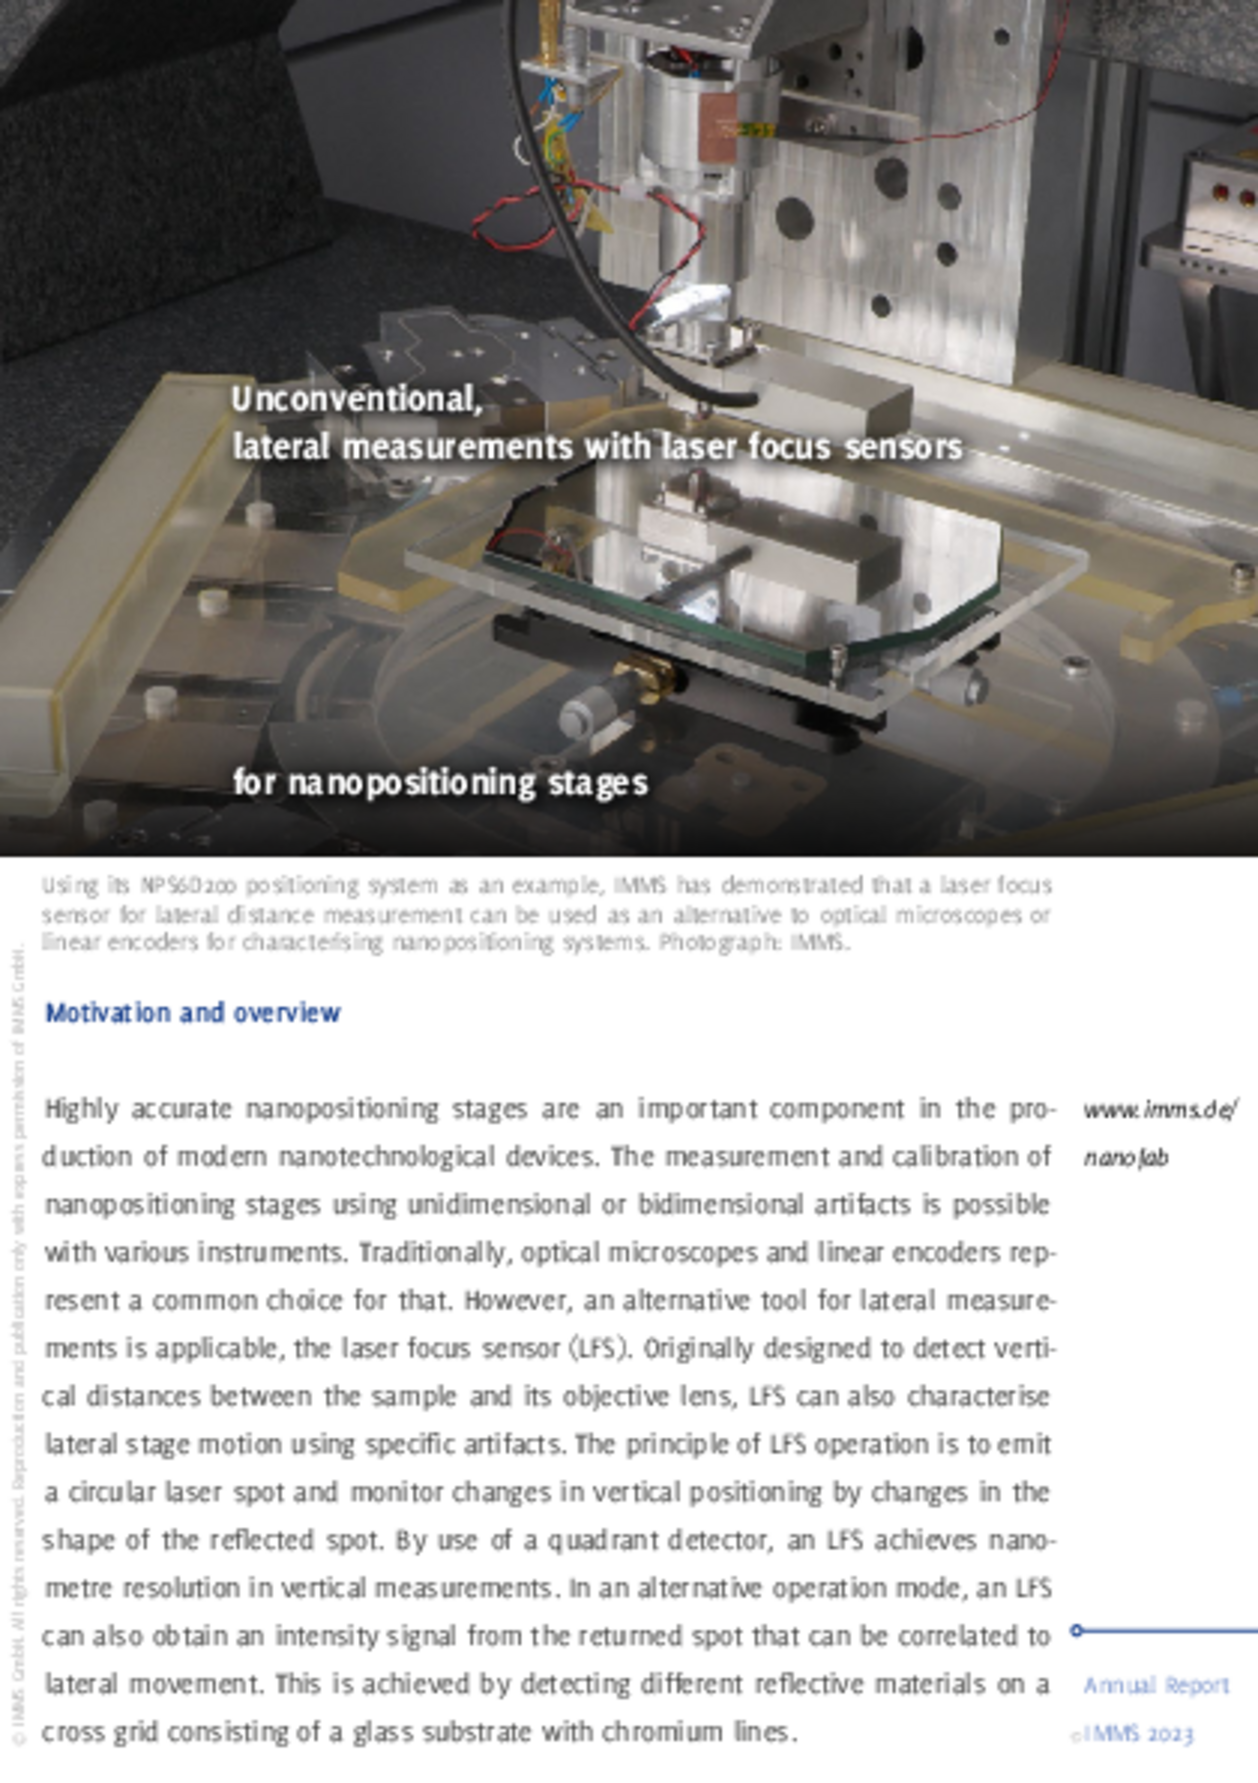
Davi Anders Brasil1, Michael Katzschmann1, Steffen Hesse1, Ludwig Herzog1, Eberhard Manske2, Thomas Fröhlich2, Thomas Kissinger2in Meas. Sci. Technol., vol. 37, no. 24, pp. 245005, 2026, DOI: doi.org/10.1088/1361-6501/ae76221IMMS Institut für Mikroelekronik- und Mechatronik-Systeme gemeinnützige GmbH (IMMS GmbH), Ehrenbergstraße 27, 98693 Ilmenau, Germany, 2Technische Universität Ilmenau, Fakultät Maschinenbau, Institut für Prozessmess- und Sensortechnik, Ehrenbergstrasse 29, 98693 Ilmenau, Germany
This might also be interesting for you
Service for R&D
Development of mechatronic systems
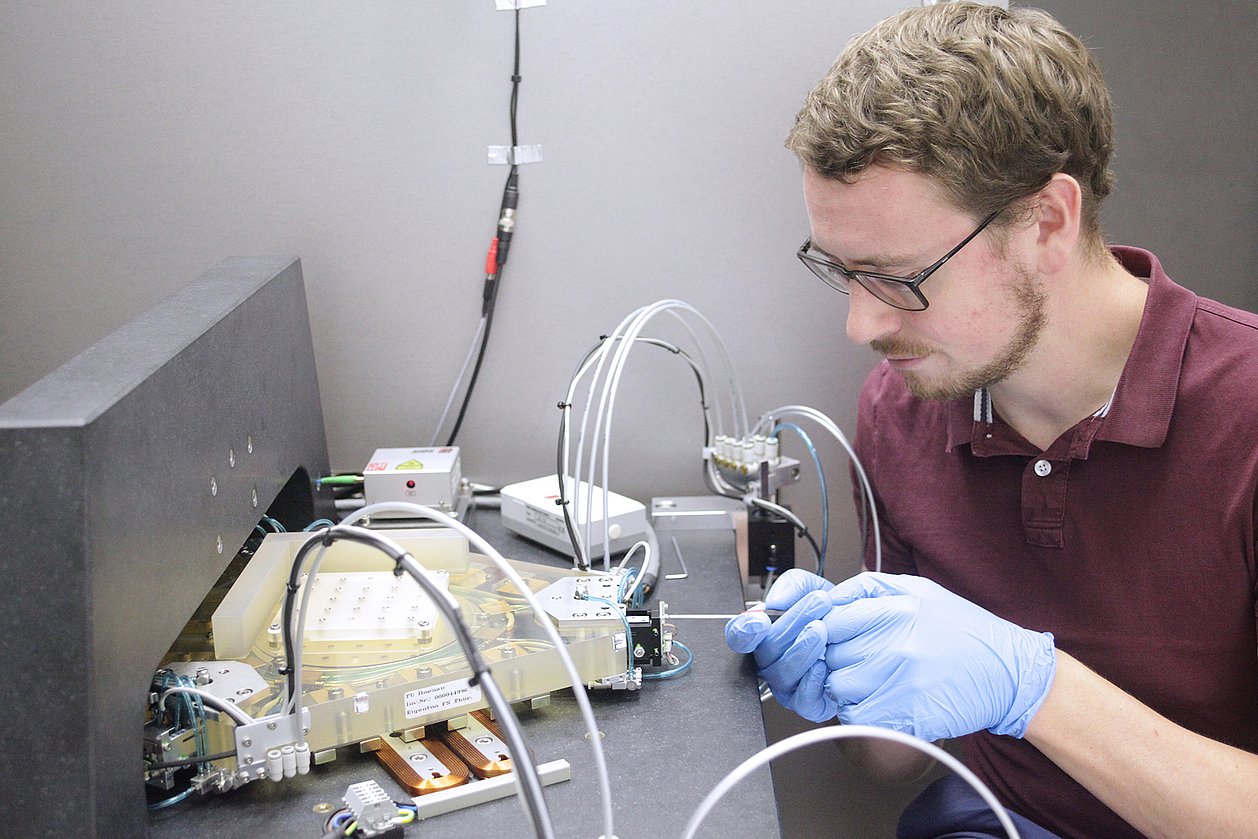
We develop actuator systems and open- and closed-loop controls as embedded solutions according to customer specifications with highest demands on precision, dynamics, available space, performance and efficiency.

Service for R&D
Finite Element Modeling
We support you in the concept and development phase of new products with calculations and simulations to shorten development times and improve product parameters such as weight & material savings or minimisation of natural vibrations.
Research field
Magnetic 6D direct drives with nm precision
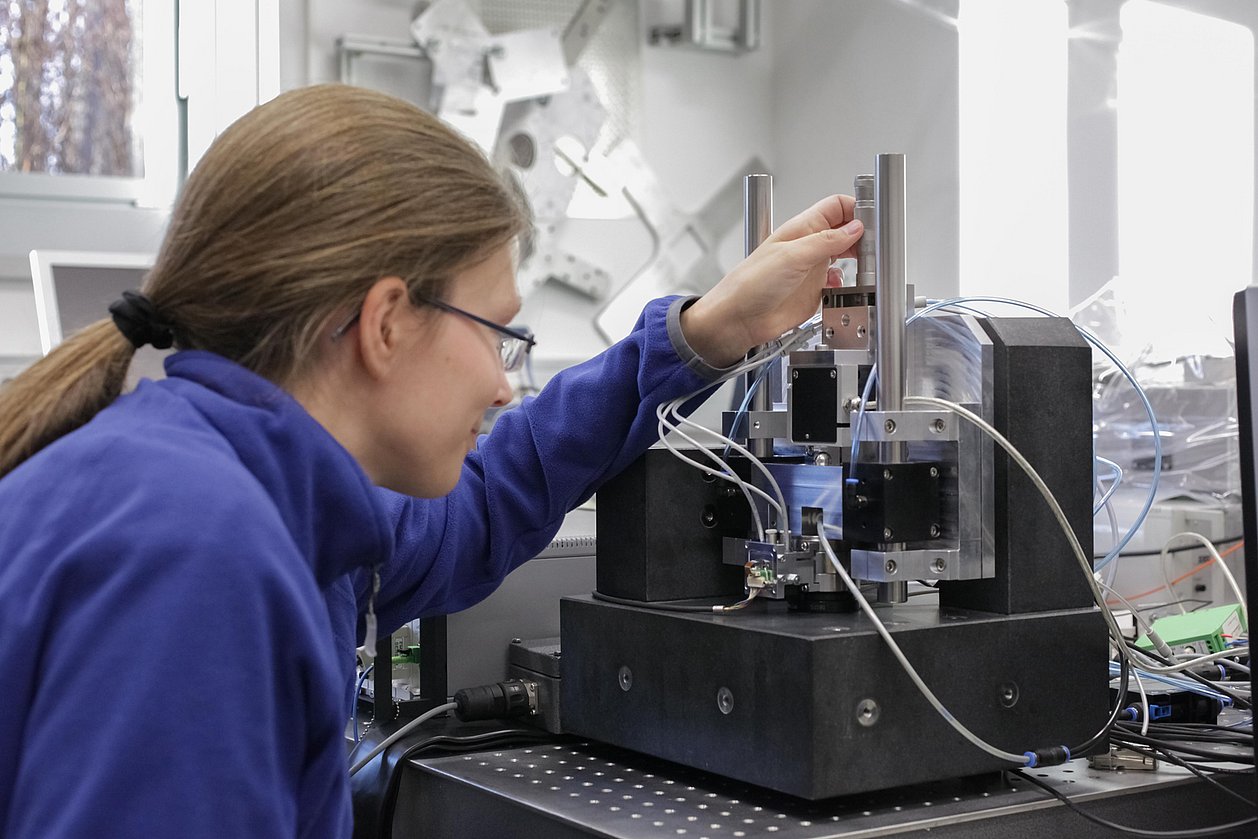
To enable the manufacturing of macroscopic high-tech products with microscopic precision, we are researching scientific principles and technical solutions for nanopositioning systems for large motion ranges.