

Current Publication
Tip-based nanofabrication below 40 nm combined with a nanopositioning machine with a movement range of Ø100 mm
Jaqueline Stauffenberg1, Michael Reibe1, Anja Krötschl2, Christoph Reuter2, Ingo Ortlepp1, Denis Dontsov3, Steffen Hesse4, Ivo W Rangelow1,5, Steffen Strehle2, Eberhard Manske1
in Micro and Nano Engineering, vol. 19, June 23, pp. 100201, 2023, DOI: doi.org/10.1016/j.mne.2023.100201
1Technische Universität Ilmenau, Fakultät Maschinenbau, Institut für Prozessmess- und Sensortechnik, Ehrenbergstraße 29, 98693 Ilmenau, Germany, 2Technische Universität Ilmenau, Institute of Micro- and Nanotechnologies, Microsystems Technology Group, Max-Planck-Ring 12, 98693 Ilmenau, Thuringia, Germany, 3SIOS Meßtechnik GmbH, Am Vogelherd 46, 98693 Ilmenau, Germany, 4IMMS Institut für Mikroelekronik- und Mechatronik-Systeme gemeinnützige GmbH (IMMS GmbH), Ehrenbergstraße 27, 98693 Ilmenau, Germany, 5nano analytik GmbH, Ehrenbergstraße 3, 98693 Ilmenau, Thuringia, Germany
Related content

Project
NFM-100
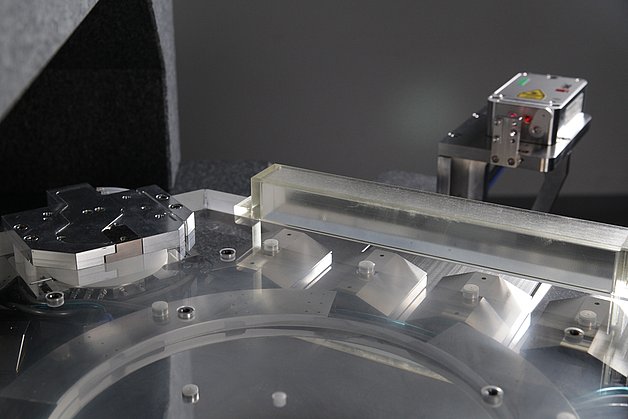
For fundamental research on nanometrology and nanofabrication at Ilmenau TU, the nanofabrication machine NFM-100 was realised as a system which enables the scanning of surfaces (AFM) as well as the processing by field emission scanning probe lithography for the first time in an xy-travel range of Ø100 mm.
Project
NanoFab
IMMS has been working on solutions for a highly dynamic drive system for multi-axis manufacturing and processing of objects with nanometre precision in the Research Training Group 2182 ”NanoFab“.
Award
iENA silver medal for "Observer of atoms - Method for sub-nm precise control of coupled over-actuated positioning systems"
Alex S. Huaman
Award